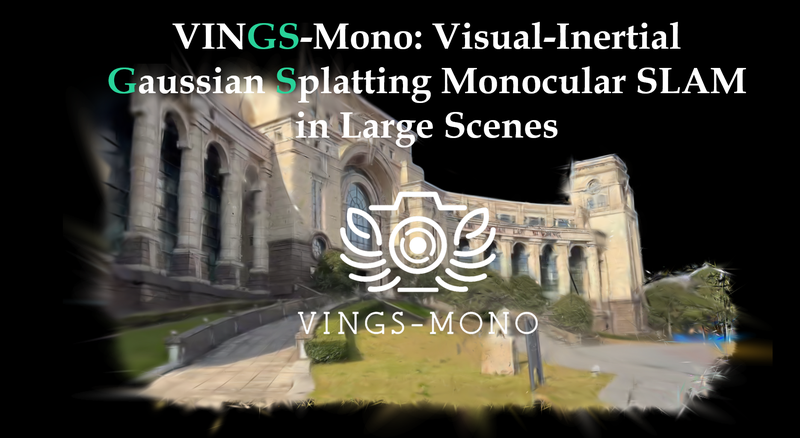
VINGS-Mono: Visual-Inertial Gaussian Splatting Monocular SLAM in Large ScenesPublished in IEEE Transactions on Robotics (T-RO) , 2025 paper | code ★305 | projectpage | videoShare on Bluesky Facebook LinkedIn Mastodon X (formerly Twitter) Previous Next