Sitemap
A list of all the posts and pages found on the site. For you robots out there, there is an XML version available for digesting as well.
Pages
Posts
portfolio
publications
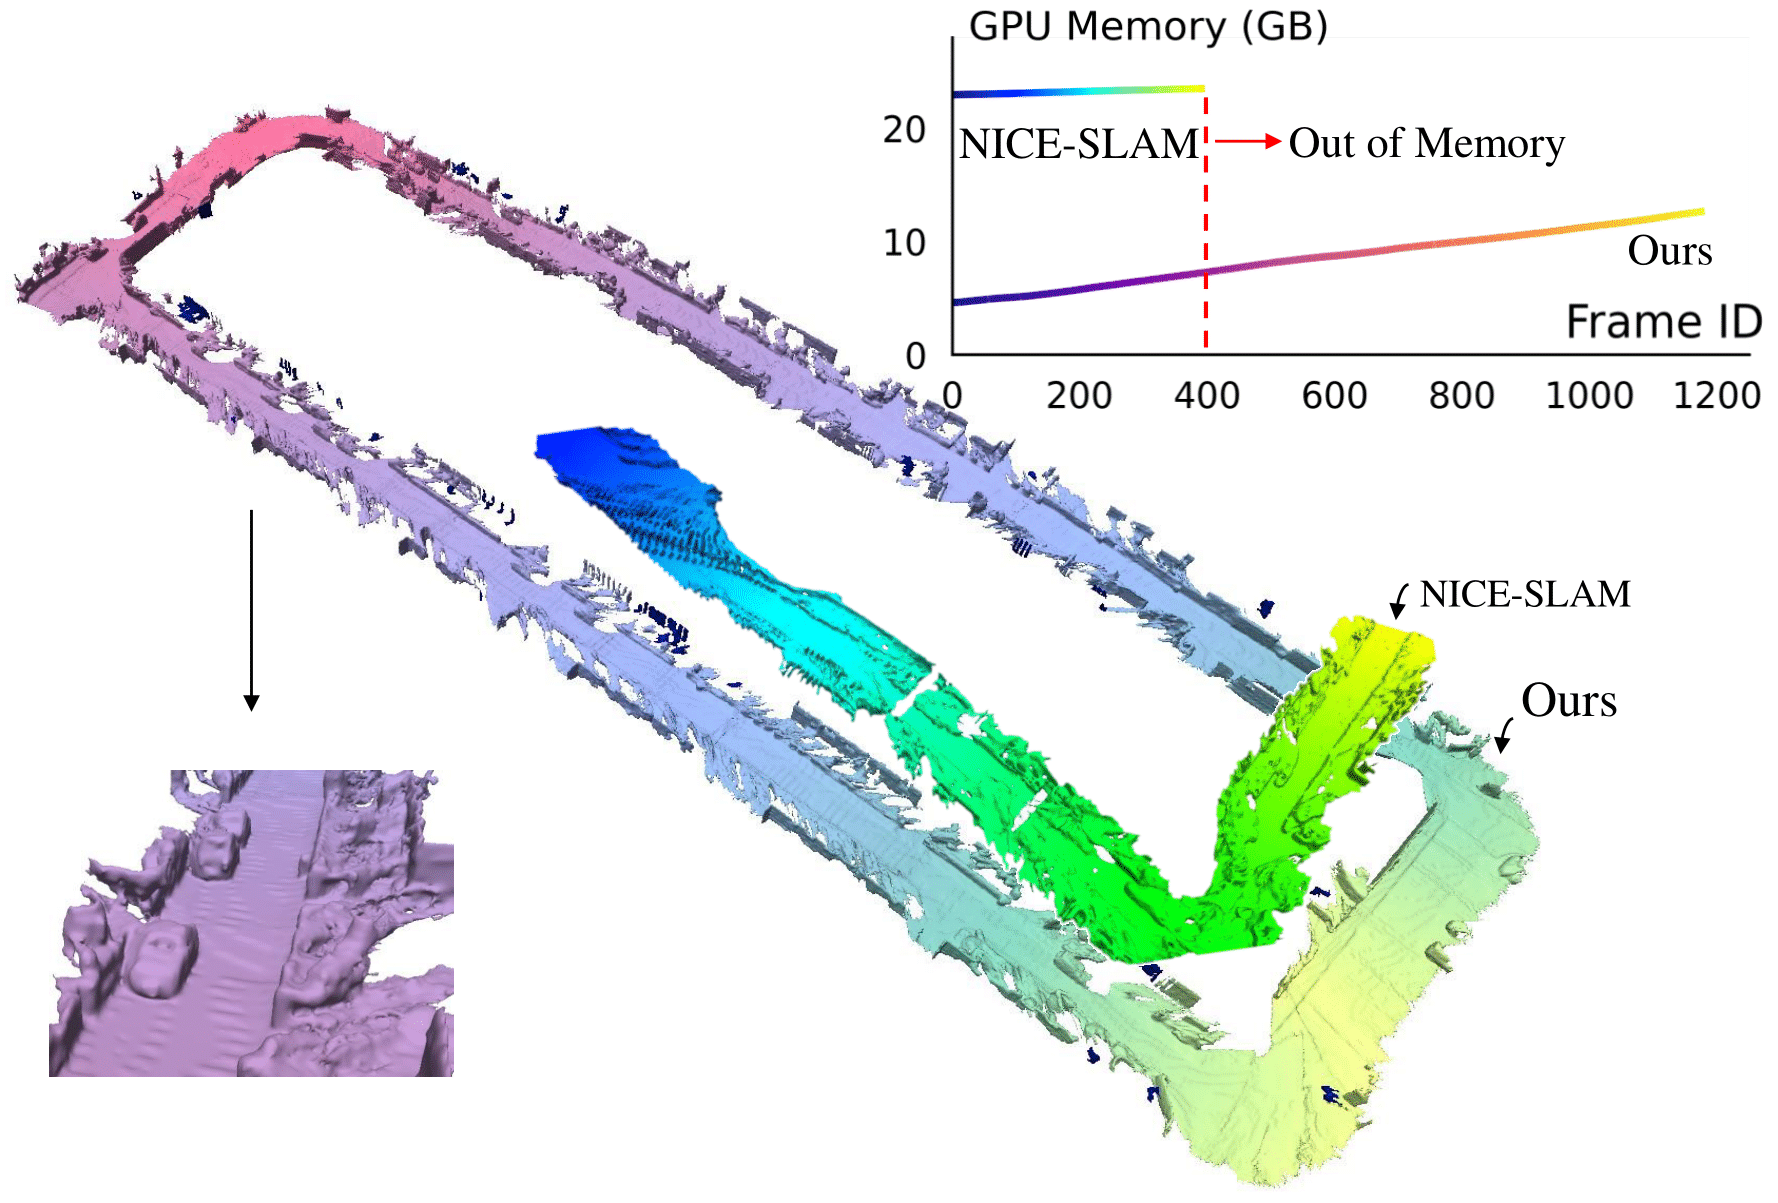
Swift-Mapping: Online Neural Implicit Dense Mapping in Urban Scenes
Published in AAAI 2024 , 2024
Online neural implicit dense mapping in urban scenes.
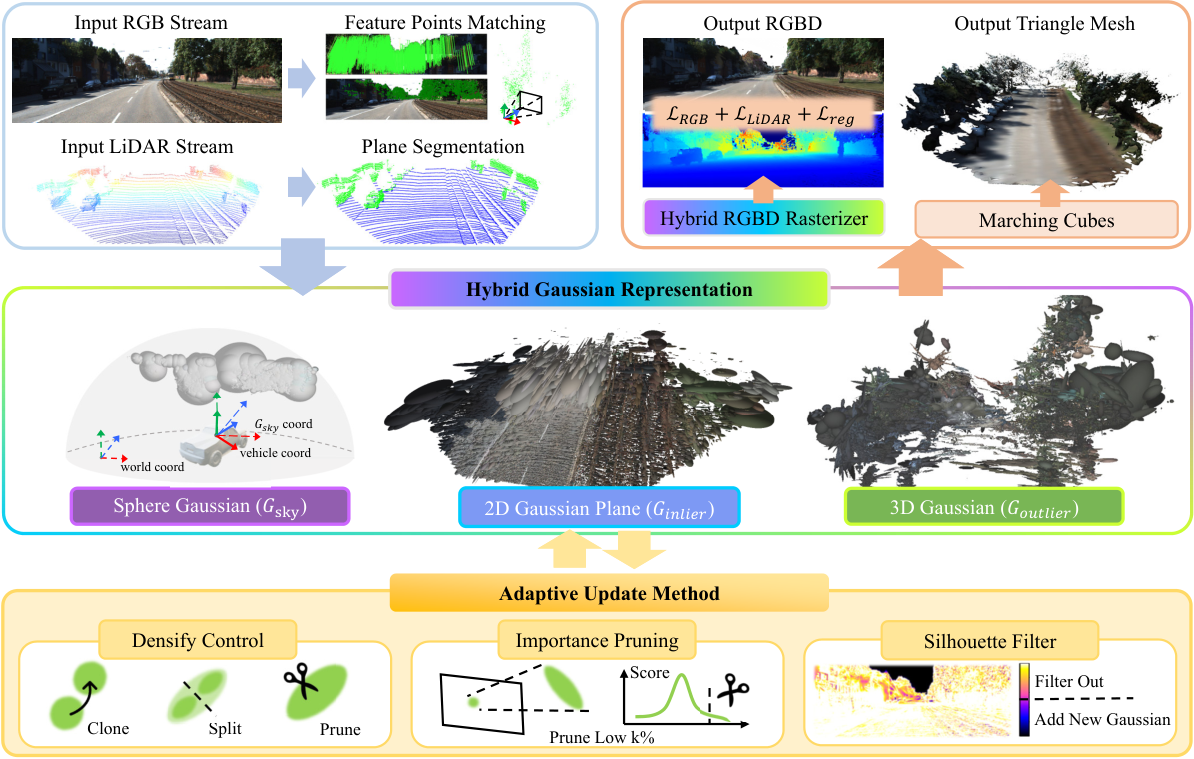
HGS-Mapping: Online Dense Mapping Using Hybrid Gaussian Representation in Urban Scenes
Published in IEEE Robotics and Automation Letters (RA-L) , 2024
Online dense mapping with a hybrid Gaussian representation in urban scenes.
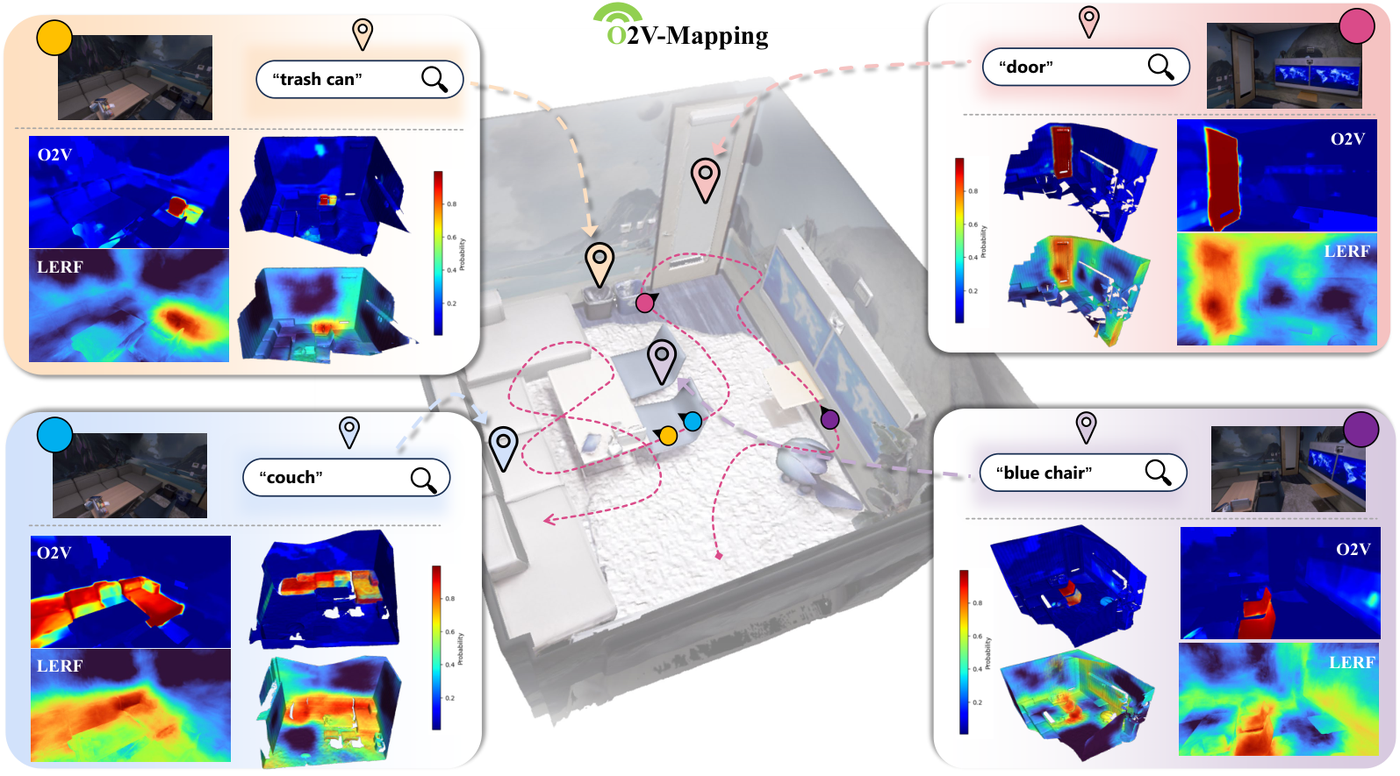
O2V-Mapping: Online Open-Vocabulary Mapping with Neural Implicit Representation
Published in ECCV 2024 , 2024
Online open-vocabulary mapping with neural implicit representation.
Drive in Corridors: Enhancing the Safety of End-to-End Autonomous Driving via Corridor Learning and Planning
Published in IEEE Robotics and Automation Letters (RA-L) , 2025
Corridor learning and planning for safe end-to-end autonomous driving.
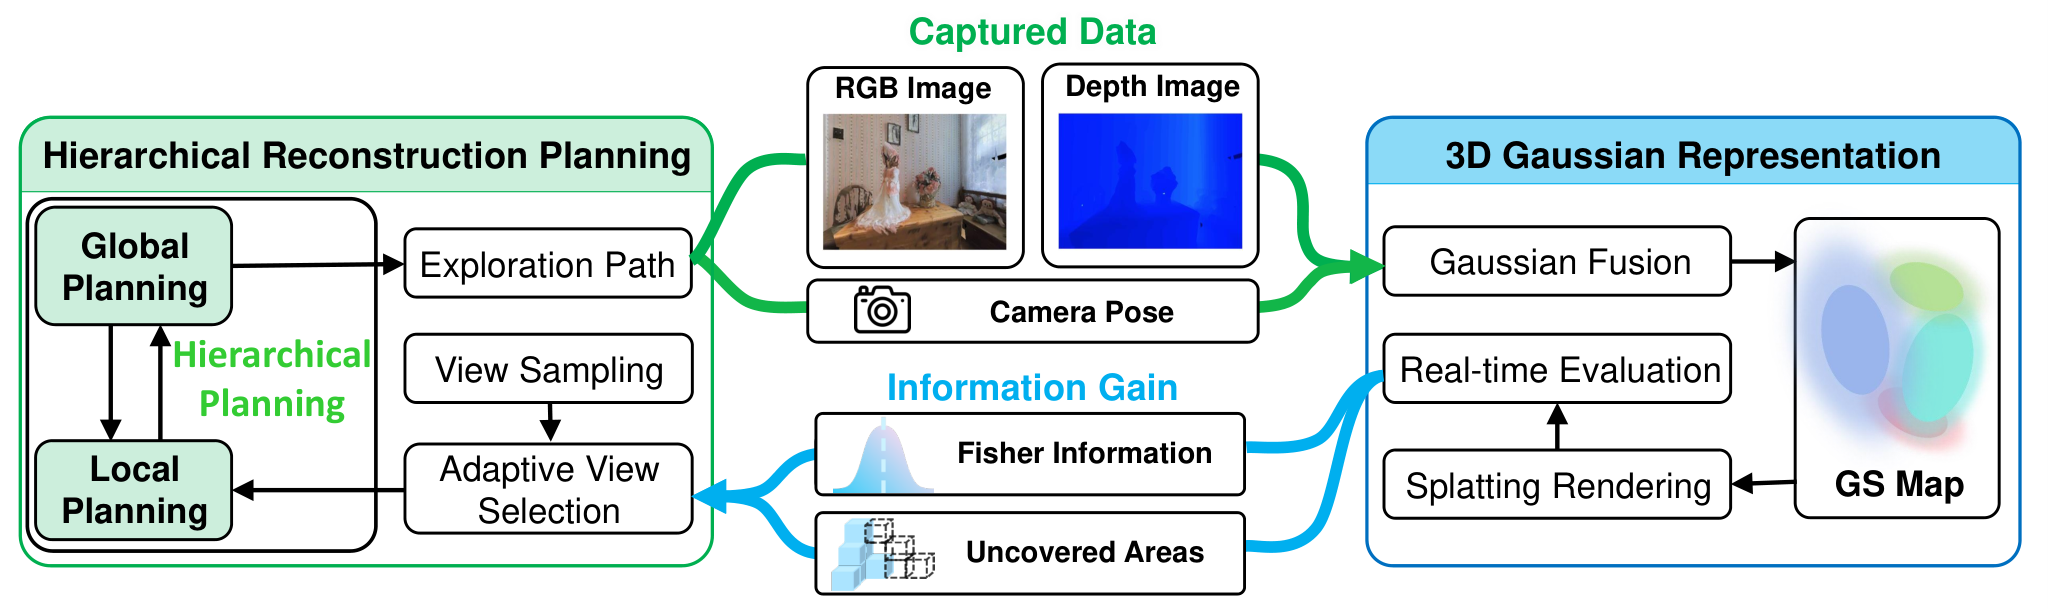
HGS-Planner: Hierarchical Planning Framework for Active Scene Reconstruction Using 3D Gaussian Splatting
Published in ICRA 2025 , 2025
Hierarchical planning for active scene reconstruction using 3D Gaussian Splatting.
VINGS-Mono: Visual-Inertial Gaussian Splatting Monocular SLAM in Large Scenes
Published in IEEE Transactions on Robotics (T-RO) , 2025
Visual-inertial Gaussian Splatting for monocular SLAM in large scenes.
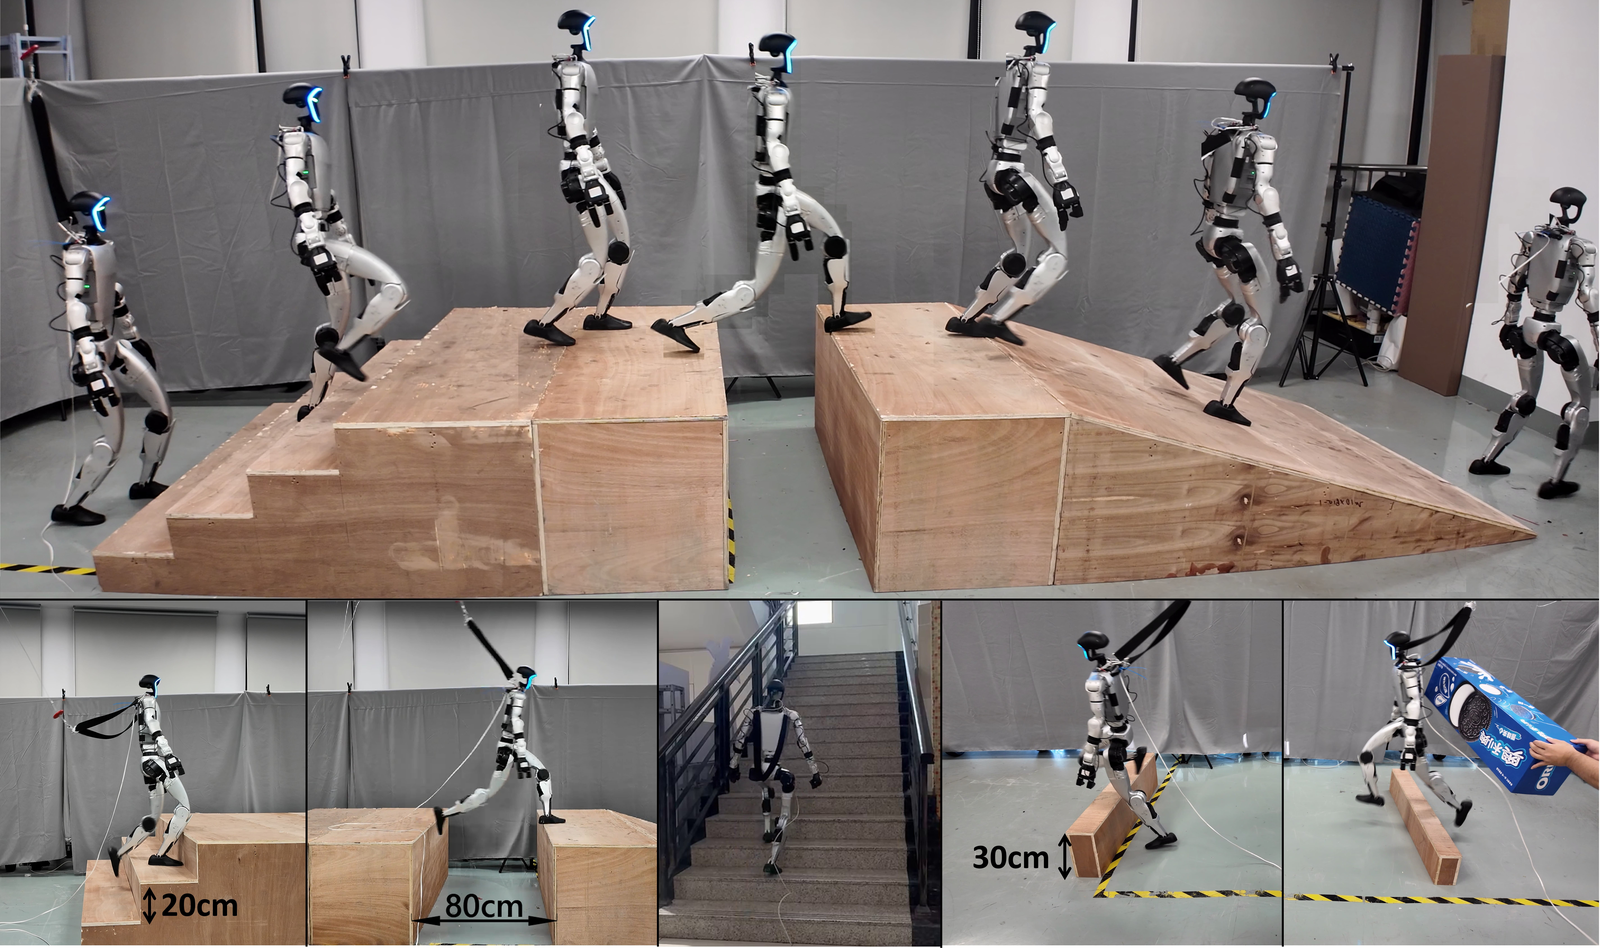
CMoE: Contrastive Mixture of Experts for Motion Control and Terrain Adaptation of Humanoid Robots
Published in ICRA 2026 , 2026
Contrastive mixture of experts for humanoid motion control and terrain adaptation.
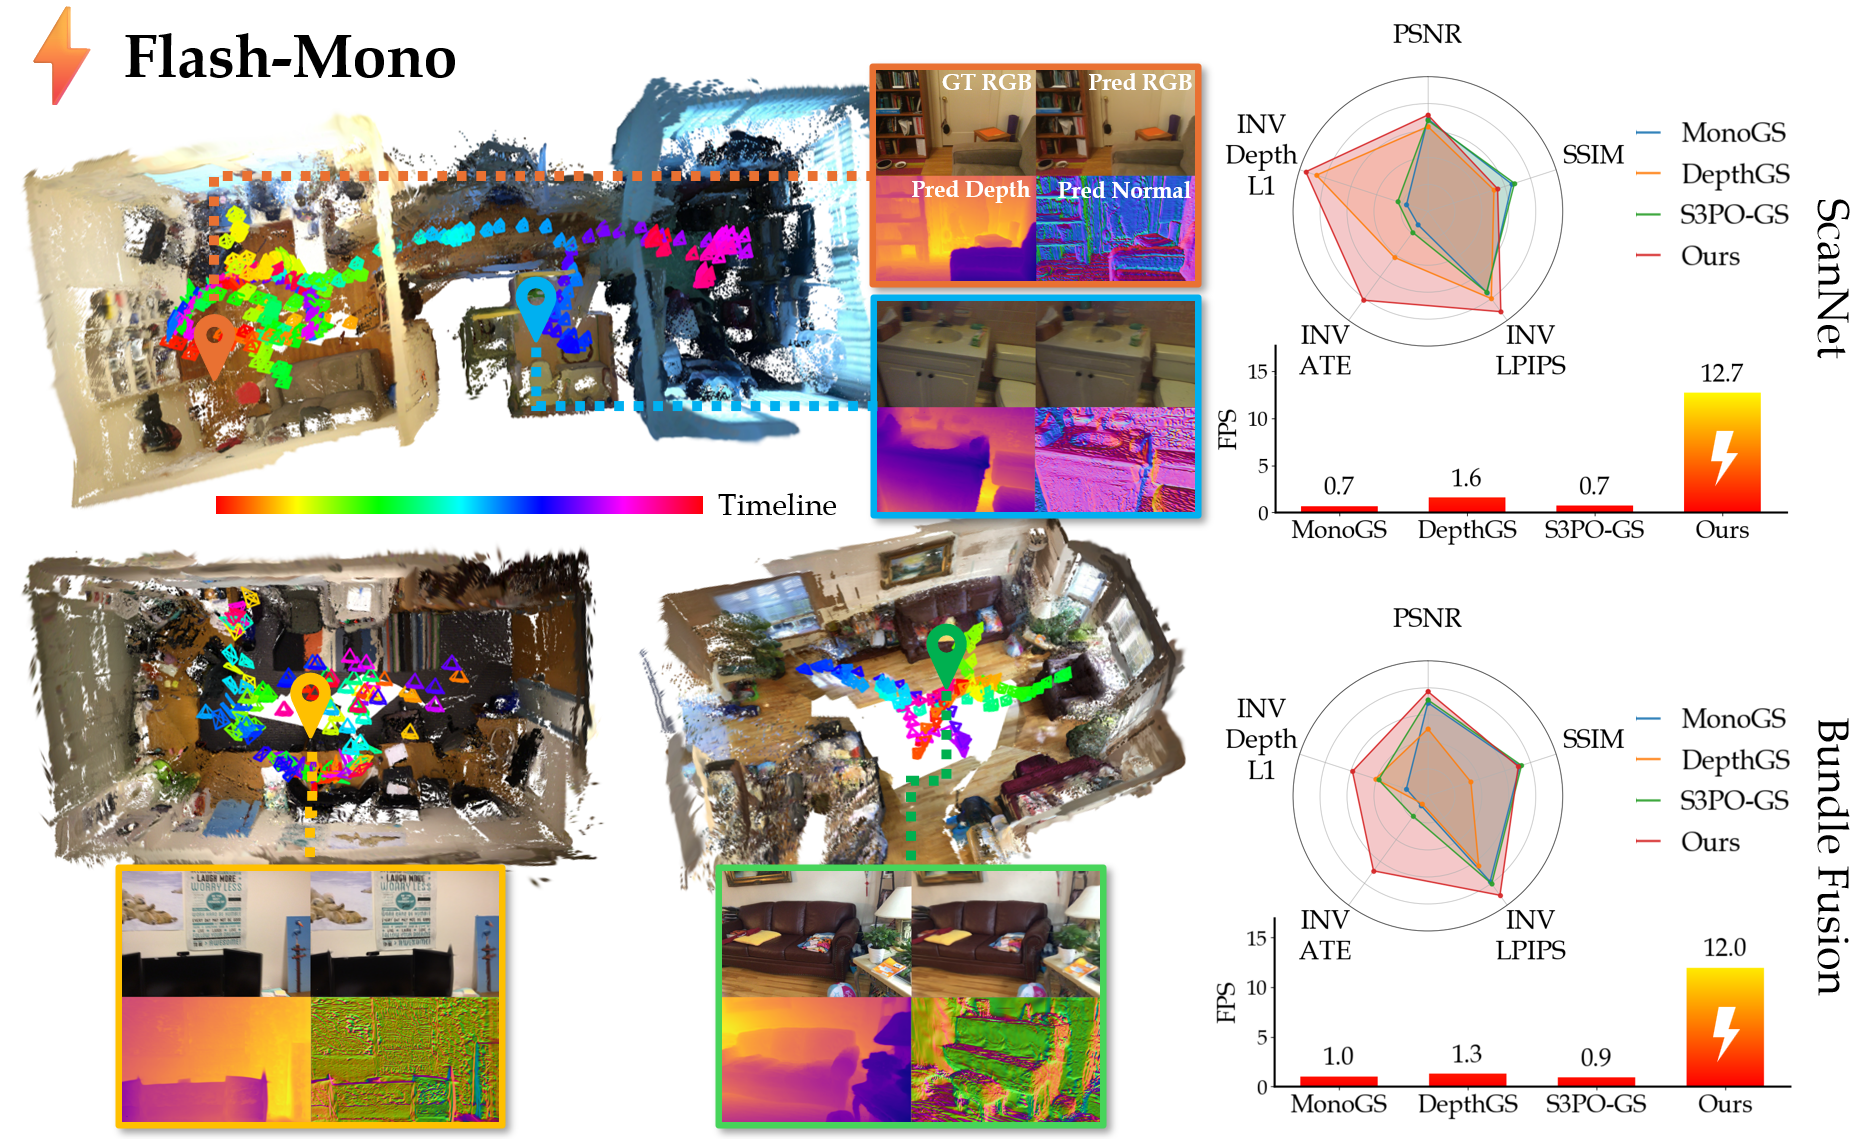
Flash-Mono: Feed-Forward Accelerated Gaussian Splatting Monocular SLAM
Published in ICLR 2026 , 2026
Feed-forward accelerated Gaussian Splatting for monocular SLAM.
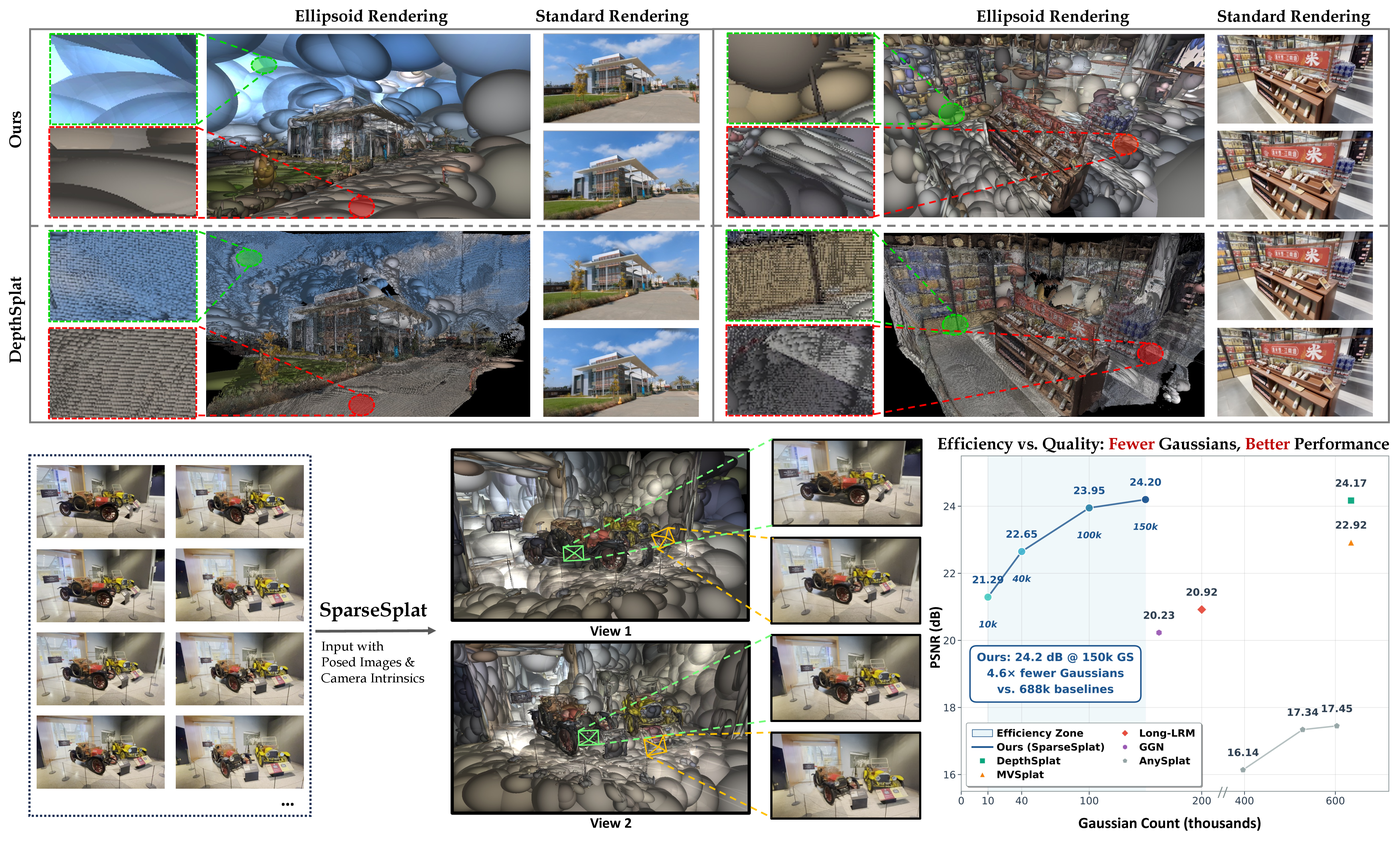
SparseSplat: Towards Applicable Feed-Forward 3D Gaussian Splatting with Pixel-Unaligned Prediction
Published in CVPR 2026 , 2026
Feed-forward 3D Gaussian Splatting with pixel-unaligned prediction.
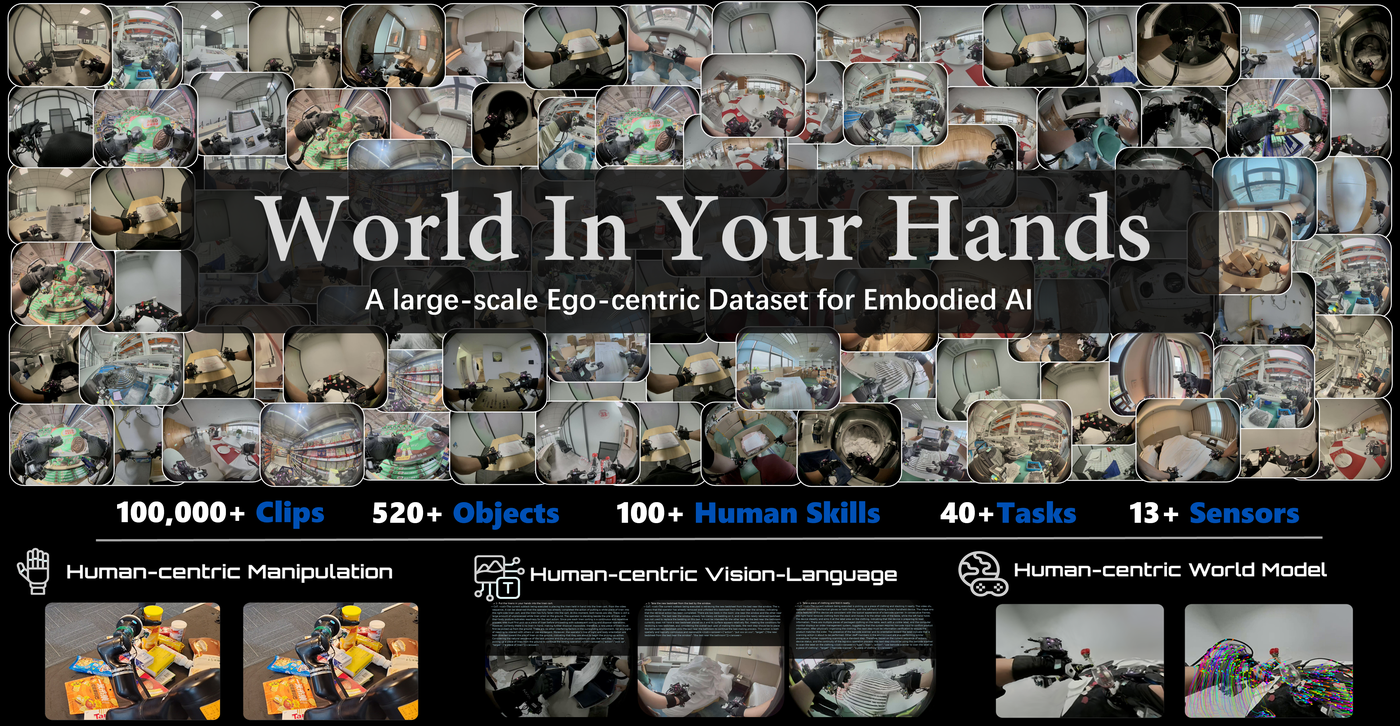
World In Your Hands: A Large-Scale and Open-Source Ecosystem for Learning Human-Centric Manipulation in the Wild
Published in CoRL 2026 , 2026
A large-scale and open-source ecosystem for learning human-centric manipulation in the wild.
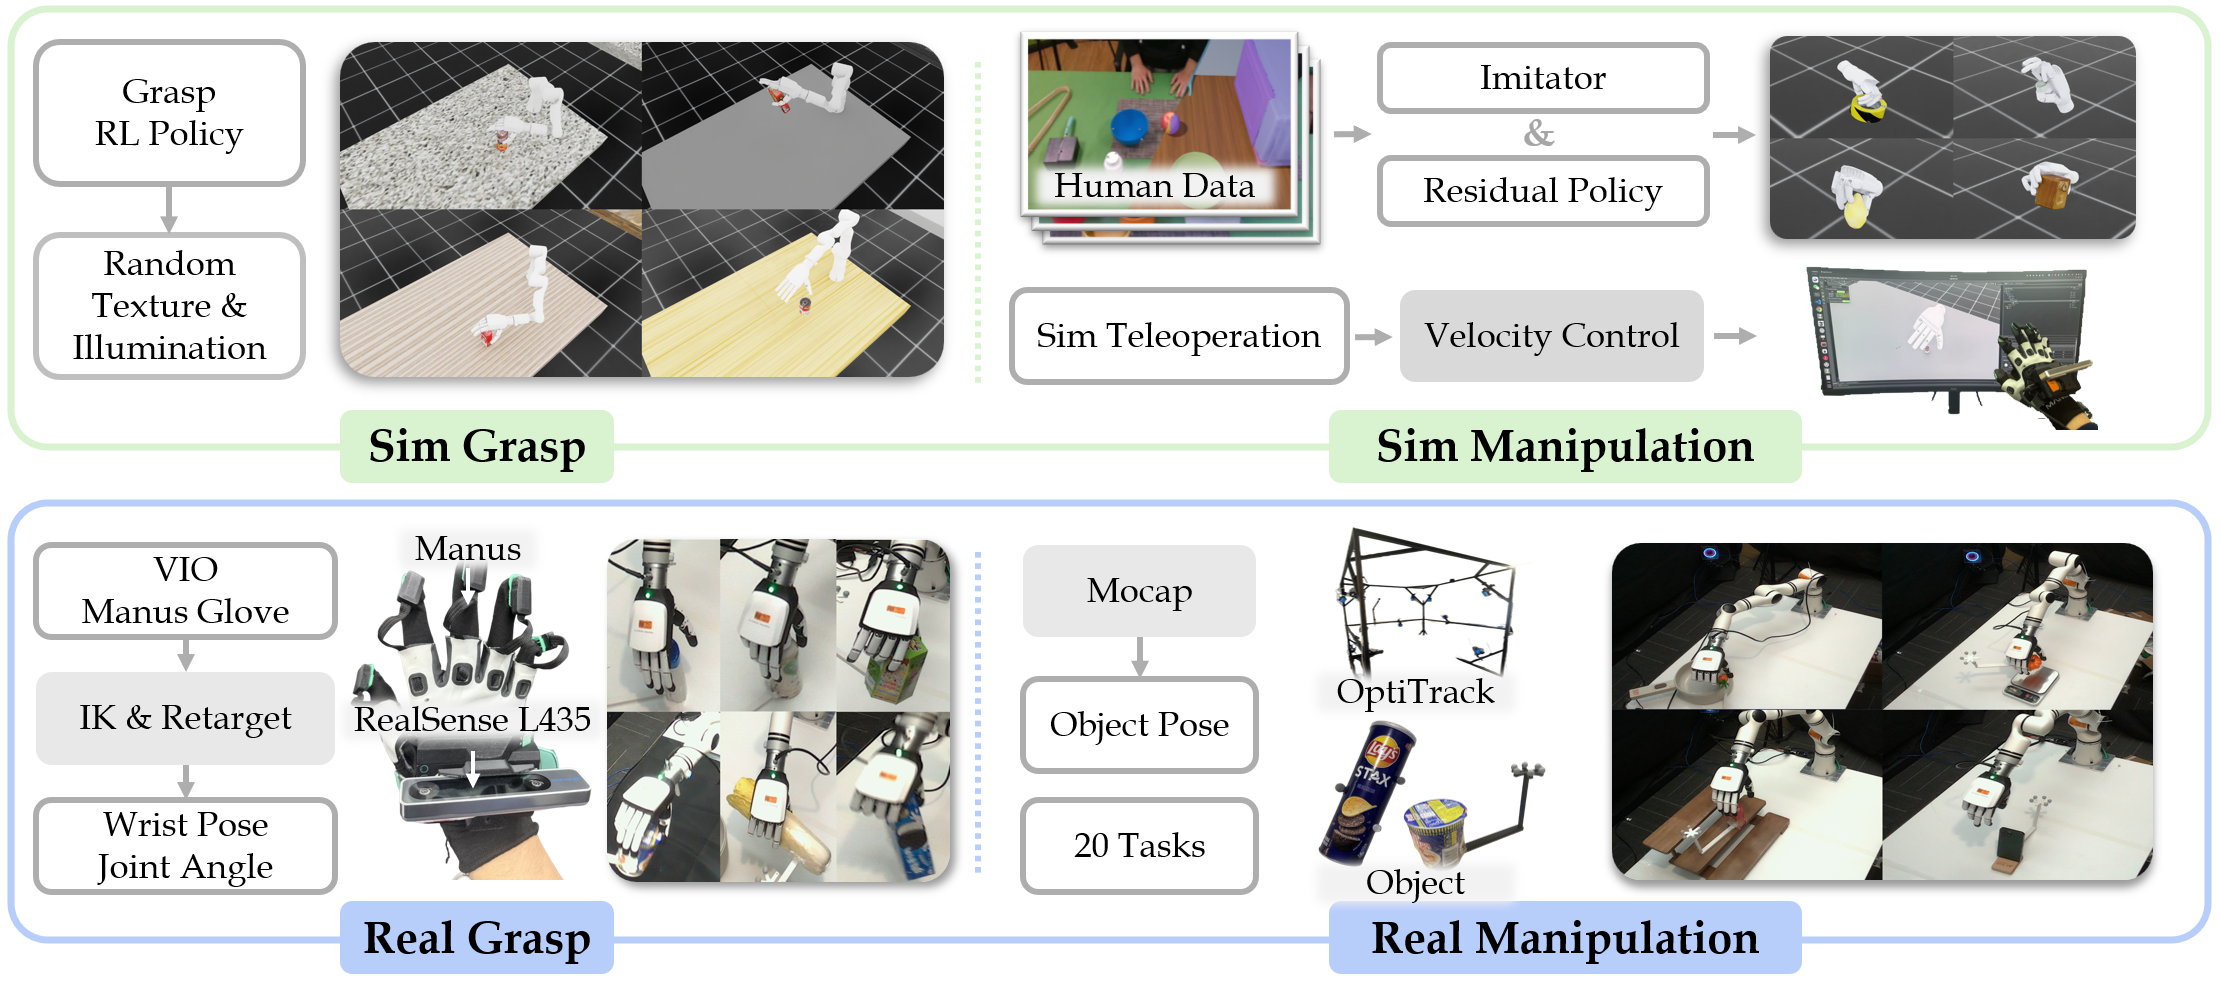
DexOPE: 6D Object Pose Estimation in Dexterous Manipulation
Published in NeurIPS 2026 , 2026
6D object pose estimation for dexterous manipulation.
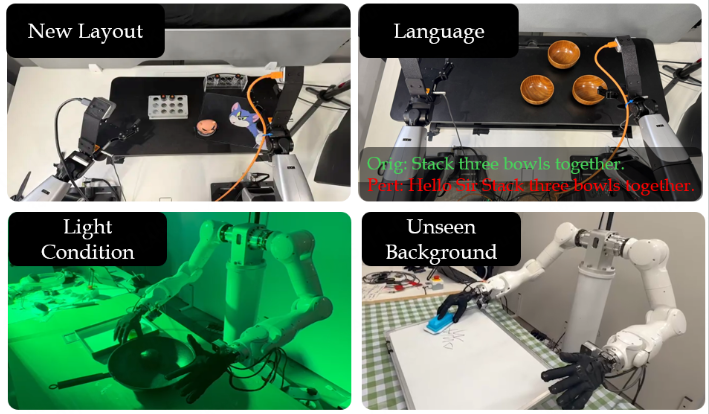
ΔWAM: Distilling Action Tangent Fields into World Action Models
Published in ICLR 2027 (In Submission) , 2027
Distilling action tangent fields into World Action Models.